IROS 2026 · Accepted · Second author
Zero-Shot Deformation Reconstruction for Soft Robots
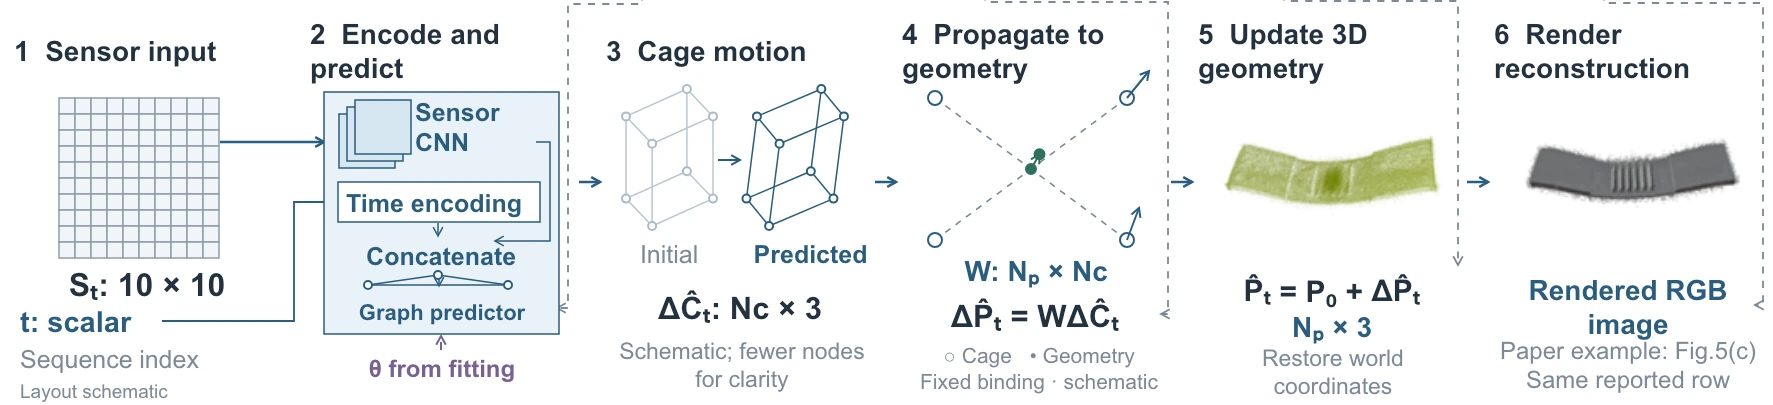
Estimating a soft robot’s changing shape from a flexible sensor array, without camera input during inference.
Physical specimenRender · frontRender · back
My work. Sensor acquisition software, experimental data collection, geometric preprocessing, model training, and evaluation.
4.7° bending / 4.9° twisting mean angle error · reported in the paper